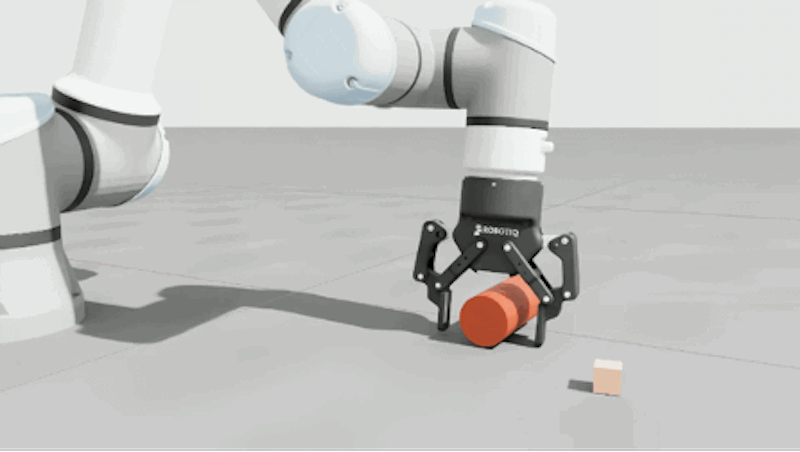
Robotiq has launched three open-source software releases for its adaptive grippers: a C++ SDK, an official ROS 2 package, and updated Nvidia Isaac Sim assets. All three are maintained and optimized by Robotiq and available now on github.com/robotiq.
Robotiq adaptive grippers have run in ROS 2 and Isaac Sim for years, mainly driven by the community of robotic developers who wrote the drivers, built the simulation models, and maintained the grippers packages on their own time so the hardware would work inside the tools they already used. That work carried the ecosystem a long way, and a good deal of it is still visible in what shipped this month.
“What changed is the demand. A physical AI application asks far more of a gripper than a conventional one ever did,’’ said Vincent Duchaine, CTO AI at Robotiq. [Read more…] about Robotiq launches open-source software tools for physical AI and robot manipulation