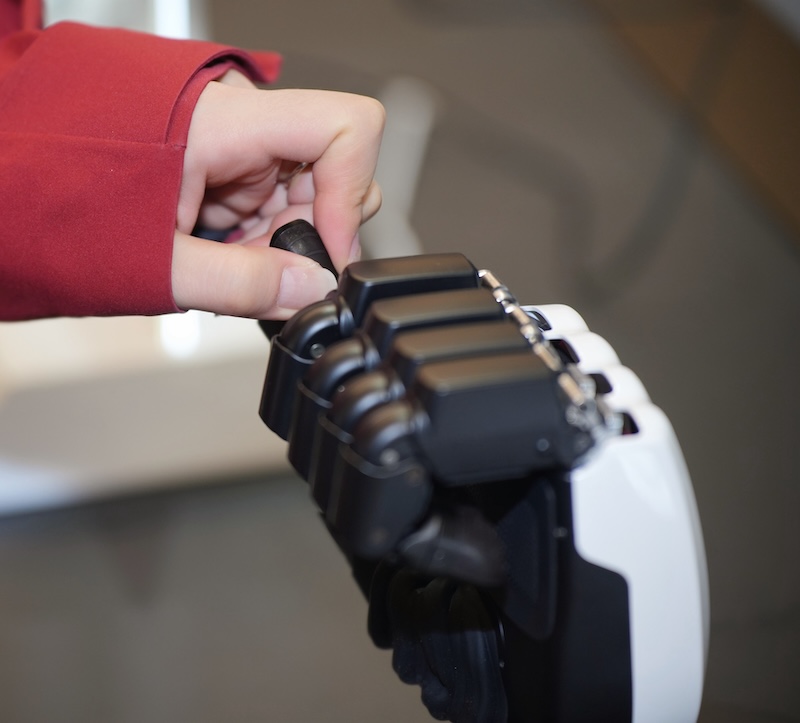
Daimon Robotics has launched Daimon-TWM, a new tactile-grounded world model designed to enable robots to interpret physical interactions such as force, friction, deformation and slippage rather than relying primarily on vision.
The Shenzhen-based robotics company says the technology is intended to address one of the major limitations of current robotic manipulation: while machine vision can identify an object and determine its position, visual information alone does not necessarily tell a robot how much force it should apply when grasping or manipulating it.
This becomes particularly important when robots handle delicate, deformable, irregular or contact-sensitive objects, where too much force can damage an item and too little can allow it to slip. [Read more…] about Daimon Robotics launches tactile AI model to give robots a sense of physical interaction