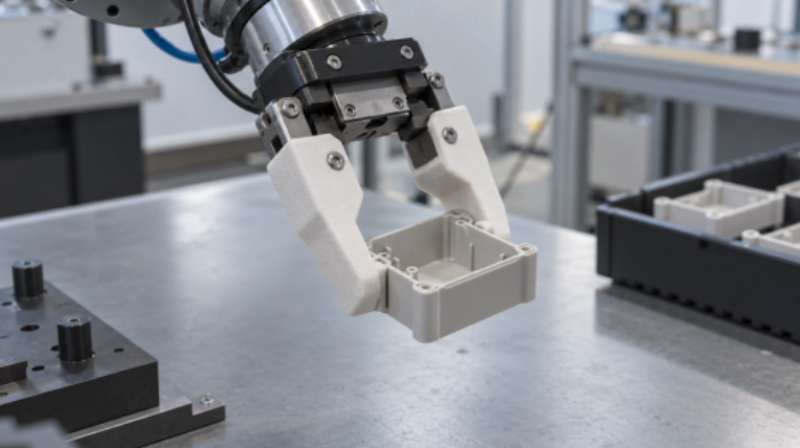
Qualifying SLS PA12 Robot Tooling Before it Enters a Production Cell
A robot gripper can look convincing on a CAD screen and still fail its first week on the line. A fingertip may slip on a slightly different part finish.
A printed bracket may flex enough to move a sensor out of position. A mounting hole may be nominally correct but leave too little room for a screw head, insert, or cable.
These are not abstract material questions. They are integration questions, and they matter most where a custom component meets a moving robot, a real workpiece, and an operator’s production target. [Read more…] about SLS PA12 Robot Tooling: A Practical Qualification Guide