Engineers evaluating active stereo cameras usually compare baseline, accuracy at range, and field of view first. Where the depth map gets computed tends to come later, often after the host computer has already been specified.
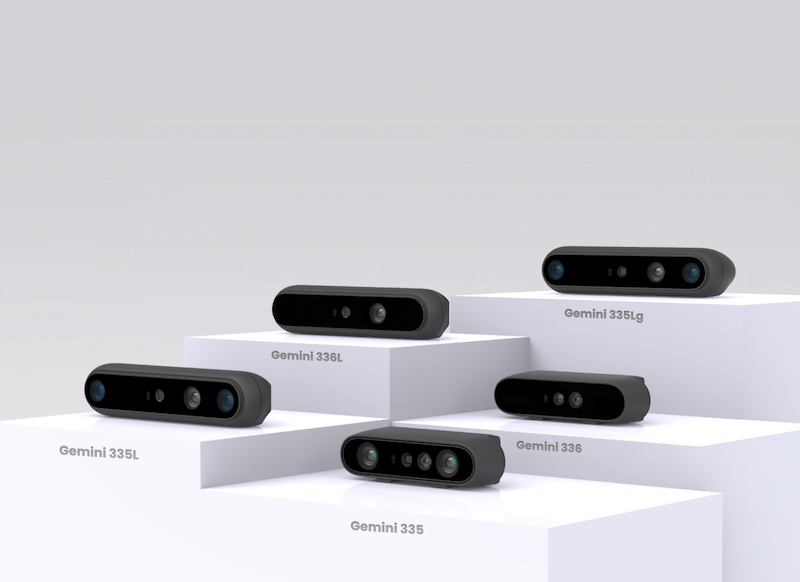
That order is backwards for many robotics and automation builds. The Orbbec Gemini 330 series active stereo cameras are a useful case study because the whole family is organized around one design decision. Every model computes depth and aligns it to color inside the camera, on Orbbec’s own MX6800 depth-engine ASIC.
The series has been shipping since Orbbec introduced the Gemini 335 and 335L in April 2024, and the lineup has since grown to cover different baselines, optical filters, interfaces, and enclosure ratings. This overview looks at what that architecture does in practice and where the family sits in the stereo vision market. [Read more…] about Orbbec Gemini 330 series: Active stereo cameras built on proprietary MX6800 ASIC depth processing