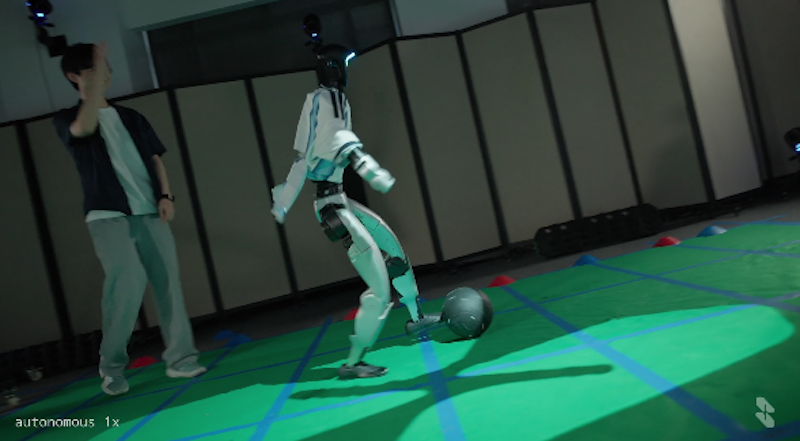
Skild AI has demonstrated a new self-play training approach that enables robots to develop physical skills without relying on human demonstrations, using its S1 robotics foundation model to learn soccer through more than 140 years of simulated play.
The company says the technique could eventually allow robots to acquire increasingly complex skills in factories, construction sites, homes and other physical environments without people having to demonstrate every action.
Skild used Nvidia Isaac Sim to create the simulated environment, giving the model a single objective: score a goal. [Read more…] about Skild AI trains robots to learn physical skills through self-play